How to calculate length of an elliptic arc

This post will show how to find the length of piece of an ellipse and explain what elliptic integrals have to do with ellipses.

Assume we have an ellipse centered at the origin with semi-major axis a and semi-minor axis b. So a > b > 0, the longest diameter of the ellipse is 2a and the shortest is 2b. The ellipse can be parameterized by

\begin{align*} x(t) &= a \cos(t) \\ y(t) &= b \sin(t) \end{align*}

Special case: quarter of an ellipse

Let’s first find the perimeter of a 1/4 of the ellipse.
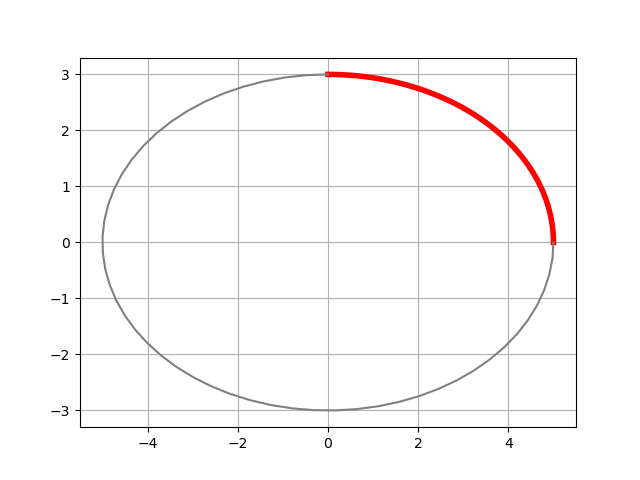
one quarter of an ellipse highlighted in red

This is given by the integral

\int_0^{\pi/2} \sqrt{a^2 \sin^2(t) + b^2 \cos^2(t)}\, dt

The change of variables u = π/2 − t turns the integral into

\begin{align*} \int_0^{\pi/2} \sqrt{a^2 \cos^2(u) + b^2 \sin^2(u)}\, du &= a \int_0^{\pi/2} \sqrt{1 - \left(1 - b^2/a^2 \right) \sin^2(u)}\, du \\ &= a E\left(1 - b^2/a^2 \right) \end{align}

because E, the “elliptic integral of the second kind,” is defined by

E(m) = \int_0^{\pi/2} \sqrt{1 - m\sin^2 t}\, dt

Therefore the perimeter of the entire ellipse is 4aE(1 − b²/a²). Let’s define

m = 1 - b^2/a^2

for the rest of the post. Incidentally, m = e² where e is the eccentricity of the ellipse.

General case

Now let’s find the length of an arc where t ranges from 0 to T and T is not necessarily π/2.
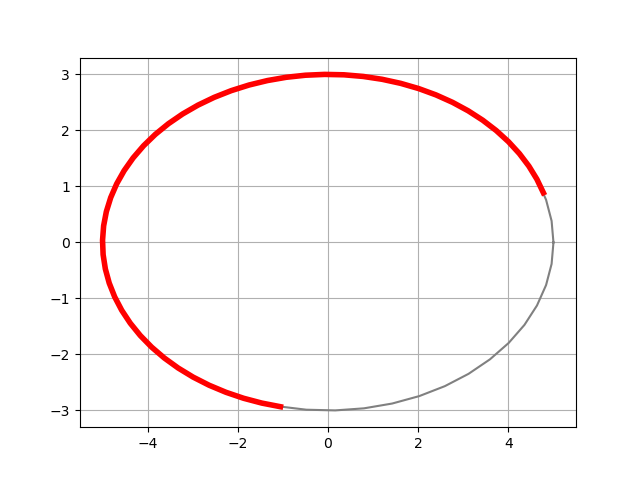
general elliptic segment highlighted in red

The derivation is similar to that above.

\begin{align*} \int_0^T \sqrt{a^2\sin^2(t) + b^2\cos^2(t)}\, dt &= \int_{\pi/2 - T}^{\pi/2} \sqrt{a^2\cos^2u + b^2\sin^2u} \, du \\ &= a E(m) - a \int_0^{\pi/2 - T} \sqrt{1 - m \sin^2u} \, du \\ &= aE(m) -aE(\pi/2 - T, m) \\ &= a E(m) + a E(T - \pi/2, m) \end{align*}

where E, now with two arguments, is the “incomplete elliptic integral of the second kind” defined by

E(\varphi, m) = \int_0^\varphi \sqrt{1 - m\sin^2(t)} \,dt

It is “incomplete” because we haven’t completed the integral by integrating all the way up to π/2.

To find the length of a general arc whose parameterization runs from t = T0 to t = T1 we find the length from 0 out to T1 and subtract the length from 0 out to T0 which gives us

a E(T_1 - \pi/2, m) - a E(T_0 - \pi/2, m)

The elliptic integrals are so named because they came out of the problem we’re looking at in this post. The integrals cannot be computed in elementary terms, so we introduce new functions that are defined by the integrals. I expand this idea in this post.

NB: We are specifying arcs by the range of our parameterization parameter t, not by the angle from the center of the ellipse. If our ellipse were a circle the two notions would be the same, but in general they are not. The central angle θ and the parameter T are related via

\begin{align*} \theta &= \arctan\left( \frac{b}{a} \tan T \right) \\ T &= \arctan\left( \frac{a}{b} \tan\theta \right) \end{align*}

I wrote about this here.

Python code

Let’s calculate the length of an arc two ways: using our formula and using numerical integration. Note that the Python implementation of the (complete) elliptic integral is ellipe and the implementation of the incomplete elliptic integral is ellipeinc. The “e” at the end of ellipe distinguishes this elliptic integral, commonly denoted by E, from other kinds of elliptic integrals.

    
    from numpy import pi, sin, cos
    from scipy.special import ellipe, ellipeinc
    from scipy.integrate import quad
    
    def arclength(T0, T1, a, b):
        m = 1 - (b/a)**2
        t1 = ellipeinc(T1 - 0.5*pi, m)
        t0 = ellipeinc(T0 - 0.5*pi, m)
        return a*(t1 - t0)
    
    def numerical_length(T0, T1, a, b):
        f = lambda t: (a**2*sin(t)**2 + b**2*cos(t)**2)**0.5
        return quad(f, T0, T1)
        
    T0, T1, a, b = 0, 1, 3, 2
    y, err = numerical_length(T0, T1, a, b)
    ell = arclength(T0, T1, a, b)
    assert(abs(ell - y) < 1e-12)

    T0, T1, a, b = 7, 1, 4, 3
    y, err = numerical_length(T0, T1, a, b)
    ell = arclength(T0, T1, a, b)
    assert(abs(ell - y) < 1e-12)

The tests pass. This increases our confidence that the derivation above is correct.
Trig in hyperbolic geometry

I recently wrote posts about spherical analogs of the Pythagorean theorem, the law of cosines, and the law of sines. The corresponding formulas for hyperbolic space mostly just replace circular functions with hyperbolic functions, i.e. replace sine with hyperbolic sine and cosine with hyperbolic cosine.

Triangles on a sphere or on a hyperbolic space like a pseudosphere have two kinds of angles: the sides come together at an angle, but the sides themselves are angles. By convention, the former are denoted with upper case letters and the latter with lower case letters.

The translation rule from spherical to hyperbolic geometry is to change functions of sides from circular to hyperbolic, but to leave functions of intersection angles alone. Or in typographical terms, put an h on the end of functions of a lower case letter but not functions of a upper case letter.

You can find these formulas, for example, in [1].

Hyperbolic Pythagorean theorem

The Pythagorean theorem on a sphere

cos(c) = cos(a) cos(b).

becomes

cosh(c) = cosh(a) cosh(b)

in hyperbolic geometry. Here you simply change cos to cosh.

Hyperbolic law of sines

The law of sines on a sphere

sin(a) / sin(A) = sin(b) / sin(B) = sin(c) / sin(C).

becomes

sinh(a) / sin(A) = sinh(b) / sin(B) = sinh(c) / sin(C).

in hyperbolic geometry. Here sin becomes sinh, but only before a lower case letter, i.e. when applied to a side.

Hyperbolic law of cosines

The law of cosines on a sphere

cos(c) = cos(a) cos(b) + sin(a) sin(b) cos(C).

becomes

cosh(c) = cosh(a) cosh(b) − sinh(a) sinh(b) cos(C).

Note the negative sign, a small exception to our conversion rule.

We could rewrite the law of cosines on a sphere to be

cos(c) = cos(a) cos(b) + κ sin(a) sin(b) cos(C)

where κ stands for curvature, which equals 1 for a unit sphere. Then our theorem translation rule holds exactly:

cosh(c) = cosh(a) cosh(b) + κ sinh(a) sinh(b) cos(C)

in a hyperbolic space with curvature κ = −1.

Related post

See this post on the Unified Pythagorean Theorem for a version of the Pythagorean theorem that holds in spherical, plane, and hyperbolic geometry.

Maybe there are analogous unified laws of sines and cosines. This is left as an exercise for the reader.

[1] William P. Thurston. Three-Dimensional Geometry and Topology, Volume 1. Princeton University Press, 1997.

Radius, circumference, and area in non-Euclidean geometry

How does the circumference of a circle vary with its radius? What about the area? The answers are simple and familiar in Euclidean geometry, but not as simple or as familiar in non-Euclidean geometry.

This post will look at how circumference and area vary as a function of radius in three spaces: a surface with constant curvature 1 (i.e. a unit sphere), a surface of constant curvature 0 (i.e. a plane), and a surface of constant curvature -1 (a hyperbolic surface). The radius in each case is the distance from the center to the circle as measured on the surface.

Spherical case

In the spherical case, a circle of radius r has circumference

C(r) = 2π sin(r)

and area

A(r) = 2π (1 − cos(r)).

The circumference formula is valid for 0 ≤ r ≤ π and the area formula is valid for 0 ≤ r ≤ π/2.

Hyperbolic case

In the hyperbolic case, a circle of radius r has circumference

C(r) = 2π sinh(r)

and area

A(r) = 2π (cosh(r) − 1).

These formulas are valid for 0 ≤ r < ∞.

Plots

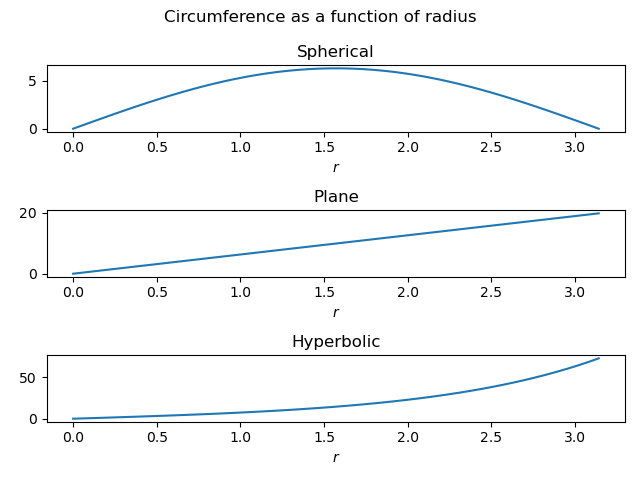
Let’s make a couple plots to illustrate the equations above. First, circumference as a function of radius.

The top subplot looks surprising at first. Can circumference decrease when radius increases? Yes, on a sphere. Imagine a circle around the north pole. As we pull that circle down from the pole, the circumference increases until the circle becomes the equator. Past that point, the circumference of the circle decreases as the circle descends further south.

Using the same range of r for all three subplots obscures the fact that the circumference of a circle in the hyperbolic case grows exponentially with the radius.

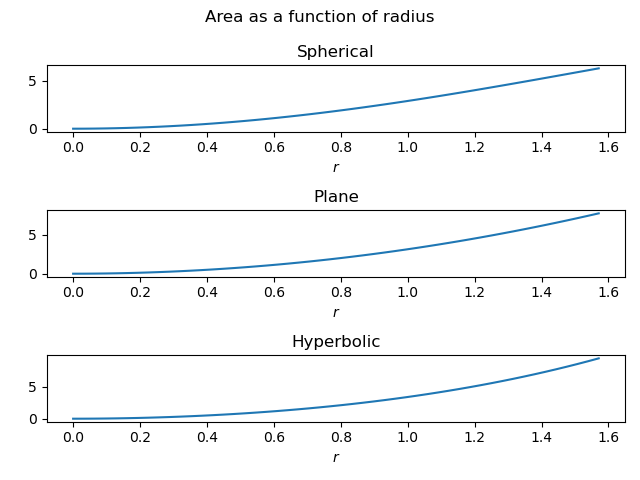
Next let’s look at area as a function of radius.

In each case, area grows approximately quadratically with radius. But again the growth in the hyperbolic case is exponential as r increases further than is possible in the spherical case.

One last note: In the plane, the ratio of area to circumference is proportional to r. In the hyperbolic case, the same ratio is asymptotically constant, independent of r.

Update

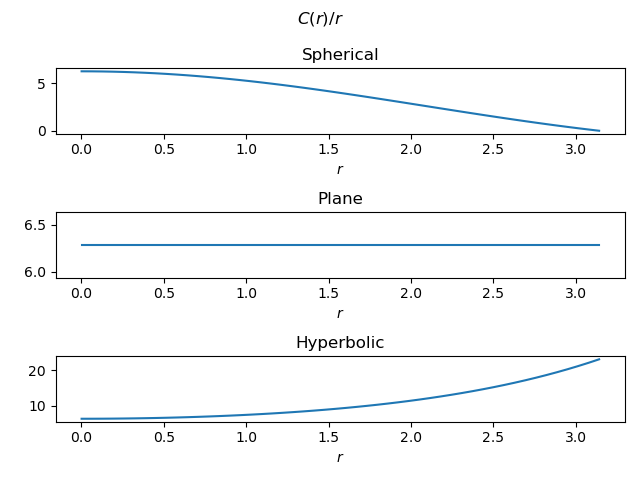
Here’s a plot of C(r) / r.

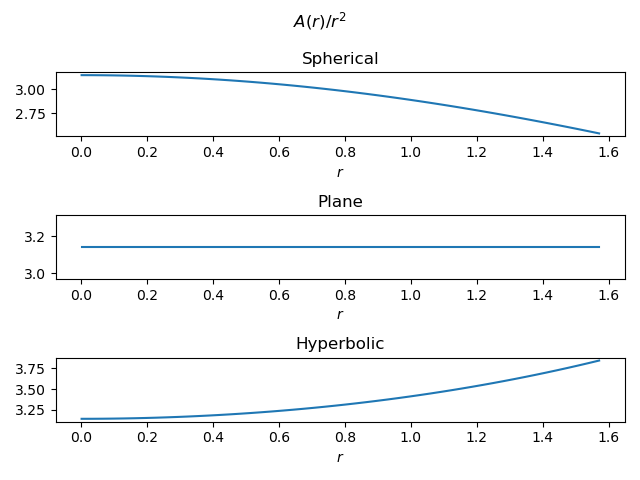
And here’s a plot of A(r) / r².

Related posts

Unified Pythagorean Theorem

A few days ago I wrote that the spherical counterpart of the Pythagorean theorem is

cos(c) = cos(a) cos(b)

where sides a and b are measured in radians. If we’re on a sphere of radius R and we measure the sides in terms of arc length rather than in radians, the formula becomes

cos(c/R) = cos(a/R) cos(b/R)

because an of length x has angular measure x/R.

How does this relate to the more familiar Pythagorean theorem on the plane? If a, b, and c are small relative to R, then the plane Pythagorean theorem holds approximately:

c² ≈ a² + b².

Unified Pythagorean Theorem

In this post I’ll present a version of the Pythagorean theorem that holds exactly on the sphere and the plane, and on a pseudosphere (hyperbolic space) as well. This is the Unified Pythagorean Theorem [1].

A sphere of radius R has curvature 1/R². A plane has curvature 0. A hyperbolic plane can have curvature k for any negative value of k.

Let A(r) be the area of a circle of radius r as measured on a surface of curvature k. Here area and radius are measured intrinsic to the surface. Then the Unified Pythagorean Theorem says

A(c) = A(a) + A(b) – k A(a) A(b) / 2π.

Plane

If k = 0, the final term on the right drops out, and we’re left with the ordinary Pythagorean theorem with both sides of the equation multiplied by π.

Sphere

On a sphere of radius R, the area of a circle of radius r is

A(r) = 2πR²(1 − cos(r/R)).

Note that for small x,

1 − cos(x) ≈ x²/2,

and so A(r) ≈ πr² when R ≫ r.  (Notation explained here.)

When you substitute the above definition for A in the unified theorem and plug in k = 1/R² you get

cos(c/R) = cos(a/R) cos(b/R)

as before.

Pseudosphere

In a hyperbolic space of curvature k < 0, let R = 1/√(-k). Then the area of a circle of radius r is

A(r) = 2πR²(cosh(r/R) − 1)

As with the spherical case, this is approximately the plane area when R ≫ r because

cosh(x) − 1 ≈ x²/2

for small x. Substituting the definition of A for hyperbolic space into the Universal Pythagorean Theorem reduces to

cosh(c/R) = cosh(a/R) cosh(b/R),

which is the hyperbolic analog of the Pythagorean theorem. Note that this is the spherical Pythagorean theorem with cosines replaced with hyperbolic cosines.

[1] Michael P. Hitchman. Geometry with an Introduction to Cosmic Topology. Theorem 7.4.7. Available here.


Approximating a golden spiral with circular arcs

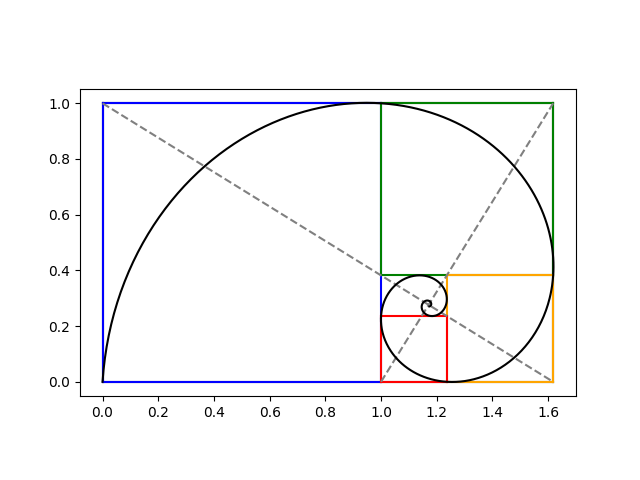
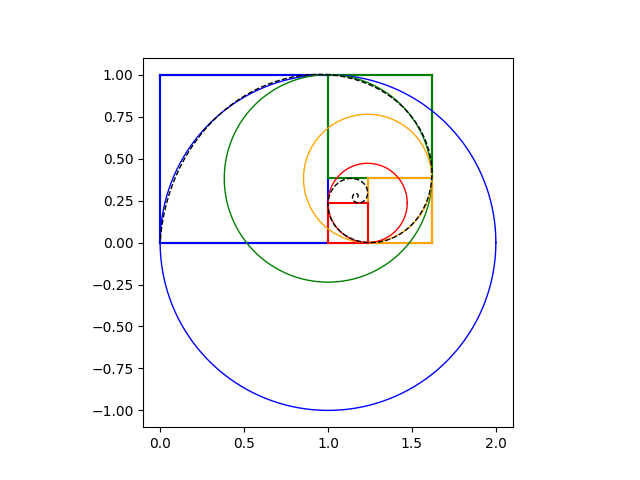
The previous post included this image of a logarithm spiral passing through the corners of squares in a sequence of golden rectangles.

The portion of the spiral in each square looks like a quarter of a circle. How well would circular arcs approximate the spiral?

Very well. Here’s a plot.

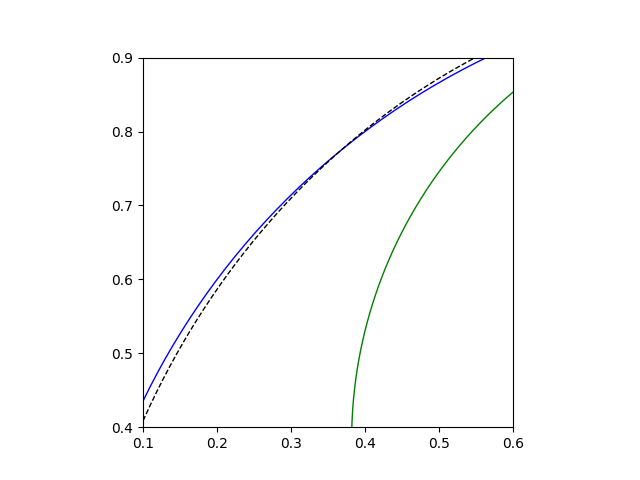
The circular arc inside the blue square is plotted in blue, the arc inside the green box in green, etc. The logarithmic spiral is plotted on top with a dashed black line. You have to zoom in closely to see any difference between the logarithmic spiral and its circular approximations.

For aesthetic applications, circular arcs are good enough and probably easier to work with. For a sort of three-dimensional analog of this approximation, see this post on the geometry of the Sydney Opera House.

Sometimes discontinuities in first or second derivatives are visually noticeable, but here they’re not. The approximation of the logarithmic spiral by a sequence of quarter circles has a jumps in curvature, which is roughly a second derivative. I suppose it’s more noticeable when curvature jumps from positive to zero or from positive to negative. Here it’s jumping from one positive value (the reciprocal of the circle radius) to another positive value (the reciprocal of a smaller radius).

Related posts

Area of spherical triangle

A few days ago I wrote about how you could calculate the area of a spherical triangle by measuring the angles at its vertices. As was pointed out in the comments, there’s a much more direct way to find the area.

Folke Eriksson gives the following formula for area in [1]. If a, b, and c are three unit vectors, the spherical triangle formed by their vertices has area E where

\tan\left(\frac{E}{2}\right) = \frac{|\mathbf{a} \cdot (\mathbf{b} \times \mathbf{c})|}{1 + \mathbf{a}\cdot \mathbf{b} + \mathbf{b}\cdot \mathbf{c} + \mathbf{a}\cdot \mathbf{c}}

Let’s try the formula out with an example and compare the area to that of a flat triangle. We’ll pick three cities as our three points, assuming the earth is a unit sphere.

Let a = Austin, Texas, b = Boston, Massachusetts, and c = Calgary, Alberta. The spherical coordinates of each point will be (1, θ, φ) where θ is longitude and φ is π/2 minus latitude.

    from numpy import *
    
    def latlong_to_cartesian(latlong):
        phi   = deg2rad( 90 - latlong[0] )
        theta = deg2rad( latlong[1] )
    
        x = sin(phi) * cos(theta)
        y = sin(phi) * sin(thea)
        z = cos(phi)
        return array([x,y,z])
    
    def spherical_area(a, b, c):
        t = abs( inner(a, cross(b, c) ) )
        t /= 1 + inner(a,b) + inner(b,c) + inner(a,c)
        return 2*arctan(t)
    
    def flat_area(a, b, c):
        x = cross(a - b, c - b)
        return 0.5*linalg.norm(x)
    
    # Latitude and longitude
    austin  = (30.2672,  97.7431)
    boston  = (42.3584,  71.0598)
    calgary = (51.0501, 114.0853)
    
    a = latlong_to_cartesian(austin)
    b = latlong_to_cartesian(boston)
    c = latlong_to_cartesian(calgary)
    
    round = spherical_area(a, b, c)
    flat  = flat_area(a, b, c)
    print(round, flat, round/flat)

This shows that our spherical triangle has area 0.0900 and the corresponding Euclidean triangle slicing through the earth would have area 0.0862, the former being 4.467% bigger.

Let’s repeat our exercise with a smaller triangle. We’ll replace Boston and Calgary with Texas cities Boerne and Carrollton.

    boerne  = (29.7947, 98.7320)
    carrollton = (32.9746, 96.8899)

Now we get area 0.000302 in both cases. The triangle is so small relative to the size of the earth that the effect of the earth’s curvature is negligible.

In fact the ratio of the two computed areas is 0.9999, i.e. the spherical triangle has slightly less area. The triangle is so flat that numerical error has a bigger effect than the curvature of the earth.

How could we change our code to get more accurate results for small triangles? That would be an interesting problem. Maybe I’ll look into that in another post.

[1] “On the measure of solid angles”, F. Eriksson, Math. Mag. 63 (1990) 184–187.

Triangles on a pseudosphere

The previous post was about triangles on a sphere. This post will be about triangles on a pseudosphere.

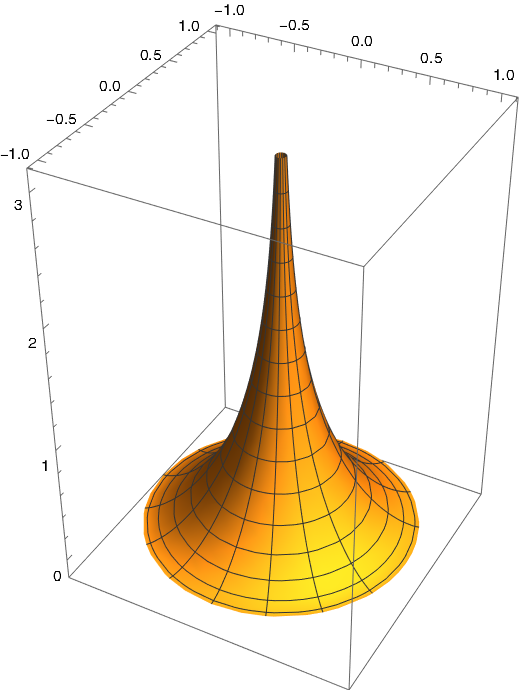
A pseudosphere looks something like the bell of a trumpet or a trombone.

Here’s a plot of a pseudosphere.

This was created in Mathematica with the code

    ParametricPlot3D[
        {   
            Cos[p] Sech[t],
           -Sin[p] Sech[t],
            t - Tanh[t] 
        },
        {t,  0, 4},
        {p, 0, 2 Pi}
    ]

The pseudosphere has constant negative curvature just as the sphere has constant positive curvature.

By curvature I mean specifically Gaussian curvature, the product of the sectional curvature in orthogonal directions at each point. A sphere curves the same way in all directions. A pseudosphere curves opposite ways in different directions. Coordinate lines through a point are convex in one direction and concave in another. Their sectional curvatures have opposite signs and so their product is negative.

A spherical triangle is formed by great circles connecting the vertices of the triangles. Great circles are the geodesics on a sphere.

A pseudospherical triangle is a triangle formed by geodesics on the pseudosphere. These are the “straight” lines in the hyperbolic geometry of the surface.

On a sphere, the interior angles of a triangle add up to more than π, and in fact the amount by which the sum of the angles exceeds π is proportional to the area of the triangle.

On a pseudosphere, the interior angles of a triangle add up to less than π. And just as in the case of the sphere, the difference between the sum of the angles and π, now negative, is proportional to the area. This result was discovered by Johann Heinrich Lambert (1728–1777).

On a sphere or a pseudosphere, the interior angles of a small triangle add up to nearly π. As triangles get larger, the sum increases on a sphere but decreases on a pseudosphere.

The general principle behind both of these cases is the local Gauss-Bonnet theorem. For any surface, let T be triangle whose sides are geodesics. Then the integral of the Gaussian curvature over T is equal to the sum of the interior angles of T minus π.

When a surface has constant curvature, the integral of curvature over a region is proportional to the area of the region. So on a sphere or pseudosphere, the area of a geodesic triangle is proportional to the sum of the interior angles minus π.

The local Gauss-Bonnet theorem holds when the sides of a triangle are not geodesics, but in that case the theorem has an extra term, the integral of the geodesic curvature along the sides. Since the geodesic curvature of a geodesic is zero, this term drops out for geodesic triangles.

Related posts

Visual geometry

If you’re puzzled by the title of this post, allow me to explain.

A natural reaction would be “Isn’t geometry intrinsically visual?” Indeed, geometry is motivated by things we can visualize. But modern developments of geometry have become heavy with formal machinery, so much so that one could reasonably ask “What happened to the geometry?”

Tristan Needham has a new book entitled Visual Differential Geometry and Forms that aims to put the geometry back into a first course on differential geometry. I expect it’s a good read based on having read his previous book Visual Complex Analysis.

I just got a review copy in the mail, and flipping through the book I can see that it lives up to its title. It has lots of illustrations, just as you’d expect from a book on differential geometry if you hadn’t taken courses in the subject.

Calculating dogleg severity

Dogleg severity (DLS) is essentially what oilfield engineers call curvature.

Oil wells are not simply vertical holes in the ground. The boreholes curve around underground, even if the intent is to drill a perfectly straight hole. With horizontal drilling the curvature can be substantial.

Dogleg severity is calculated by measuring inclination and azimuth every 100 feet along a well. Inclination is the angle the hole makes with the vertical axis, like the angle φ in spherical coordinates, 90° minus the latitude. Azimuth is the angle of the projection of the well to a horizontal plane, like the θ or longitude angle in spherical coordinates. So if a well is nearly vertical, the inclination angles will be small. If a hole were shaped like a corkscrew, the inclination would be constant while the azimuth makes multiple rotations.

When I said 100 feet along the well, that is 100 feet of arc length. If a hole were perfectly vertical, this would be a change of 100 vertical feet, but generally it is less. If a segment were perfectly horizontal, it would be a change of 100 horizontal feet with no change in vertical depth.

Dogleg severity models a section of an oil well as a piece of a big circle. We assume our two inclination and azimuth measurements taken at two points along this circle, separated by an arc of 100 feet. If this arc makes an angle ψ, then the length of the arc is

ρ ψ = 100 ft

where ρ is the radius of the circle. Engineers call the angle ψ the dog leg angle, the angle of the sector between two measurements. Mathematicians call 1/ρ the curvature, so curvature is proportional to DLS.

To calculate curvature or DLS you have to calculate ψ from the two inclination and azimuth readings, (θ1, φ1) and (θ2, φ2). This is exactly the same as calculating distance from longitude and latitude. Instead of longitude and latitude on the earth, imagine a large sphere tangent to the wellbore at the two points where the measurements were taken. To put it another way, we imagine this section of the well as being a piece of a great circle on this sphere.

The only difference is that instead of the radius ρ being fixed and solving for distance, as in the longitude and latitude problem, our distance is fixed at 100 ft and we want to calculate ρ, or equivalently calculate ψ. From these notes we have

ψ = cos−1(cos φ1 cos φ2 + sin φ1 sin φ2 cos(θ1 − θ2)).

So, for example, suppose we had inclination 4° and azimuth 30° at one point, and inclination 7° and azimuth 40° at the next measurement, 100 ft of arc length away. Then

ψ = cos−1(cos 4° cos 7° + sin 4° sin 7° (cos40° − 30°)) = 3.138°

This says ρ = 1826 feet, i.e. our section of the well is curved like a circle of radius 1826 feet.

We could compute this in Python as follows.

    from numpy import sin, cos, arccos, deg2rad, rad2deg

    def dls(inc1, az1, inc2, az2):
        ph1 = deg2rad(inc1)
        ph2 = deg2rad(inc2)
        th1 = deg2rad(az1)
        th2 = deg2rad(az2)
        return rad2deg( arccos(
            cos(ph1)*cos(ph2) + sin(ph1)*sin(ph2)*cos(th1-th2)) )

Here we assume input and output are in degrees, but internally we do calculations in radians.

If we call dls(4, 30, 7, 40) we get back 3.138°.

Related links

Kissing circle

Curvature is a measure of how tightly a curve bends. A circle of radius r has curvature 1/r. So a small circle has high curvature and a big circle has small curvature.

In general the curvature of a curve at a point is defined to be the curvature of the circle that best fits at that point. This circle is called the osculating circle which means the circle that “kisses” the curve at that point.

From Online Etymology Dictionary:

osculate (v.) “to kiss (one another),” 1650s, from Latin osculatus, past participle of osculari “to kiss,” from osculum “a kiss; pretty mouth, sweet mouth,” literally “little mouth,” diminutive of os “mouth”

The center of the osculating circle is called the center of curvature and the radius of the circle is called the radius of curvature.

I’ll give two examples. The first is a set of ellipses that all have the unit circle as their osculating circle on the left end. So they all have curvature 1.

An ellipse with equation

\frac{x^2}{a^2} + \frac{y^2}{b^2} = 1

has varying curvature at each point. At x = −a the curvature simplifies to a/b². So to make the graph above, I used a range of values for a and set each corresponding value of b to √a.

Next, instead of fixing the osculating circle I’ll fix the curve. I’ll use the equation to fit an egg that I’ve used before and plot the osculating circles at each end. The plot below uses a = 3, b = 2, and k = 0.1.

The curvature at the fat end is a(1 − ka)/b² and the curvature at the pointy end is a(1 + ka)/b². These are derived here.

Setting k = 0 gives the curvature of an ellipse at each end used above.

More on curvature